
Human-vehicle interaction modeling
Understanding social cues, driving conventions, and behavioral adaptation in mixed traffic.
Half-day workshop
Bringing together game theory, machine learning, and control to develop autonomous vehicles that can understand social norms, reason strategically, and act safely in mixed traffic.
About the workshop
Safe navigation alone is not enough for autonomous vehicles to integrate seamlessly into mixed-traffic environments.
Autonomous vehicles must interpret implicit traffic norms, infer human intentions, and take part in cooperative or competitive interactions. This workshop examines how strategic modeling, adaptive learning, and rigorous control can work together to meet that challenge.
Through keynote presentations, invited talks, and a panel discussion, experts in multi-agent systems, reinforcement learning, human factors, and formal methods will connect high-level reasoning with robust, deployable vehicle architectures. The aim is to identify a practical research agenda for autonomous vehicles that are not only intelligent, but also socially adept and trustworthy.
Topics of interest
The workshop connects complementary perspectives across interaction, intelligence, and assurance.
Understanding social cues, driving conventions, and behavioral adaptation in mixed traffic.

Reasoning about cooperation, competition, and interdependent road-user decisions.

Combining learning and adaptation with constraints for dependable vehicle behavior.

Planning robustly when perception, prediction, and human intent remain uncertain.

Evaluating integrated approaches under realistic conditions and deployment constraints.
Invited speakers
Speaker · Primary organizer
The University of Hong Kong HKU
Presentation

Invited speaker
Nanyang Technological University NTU
Presentation
Invited speaker
University of New Brunswick UNB
Presentation
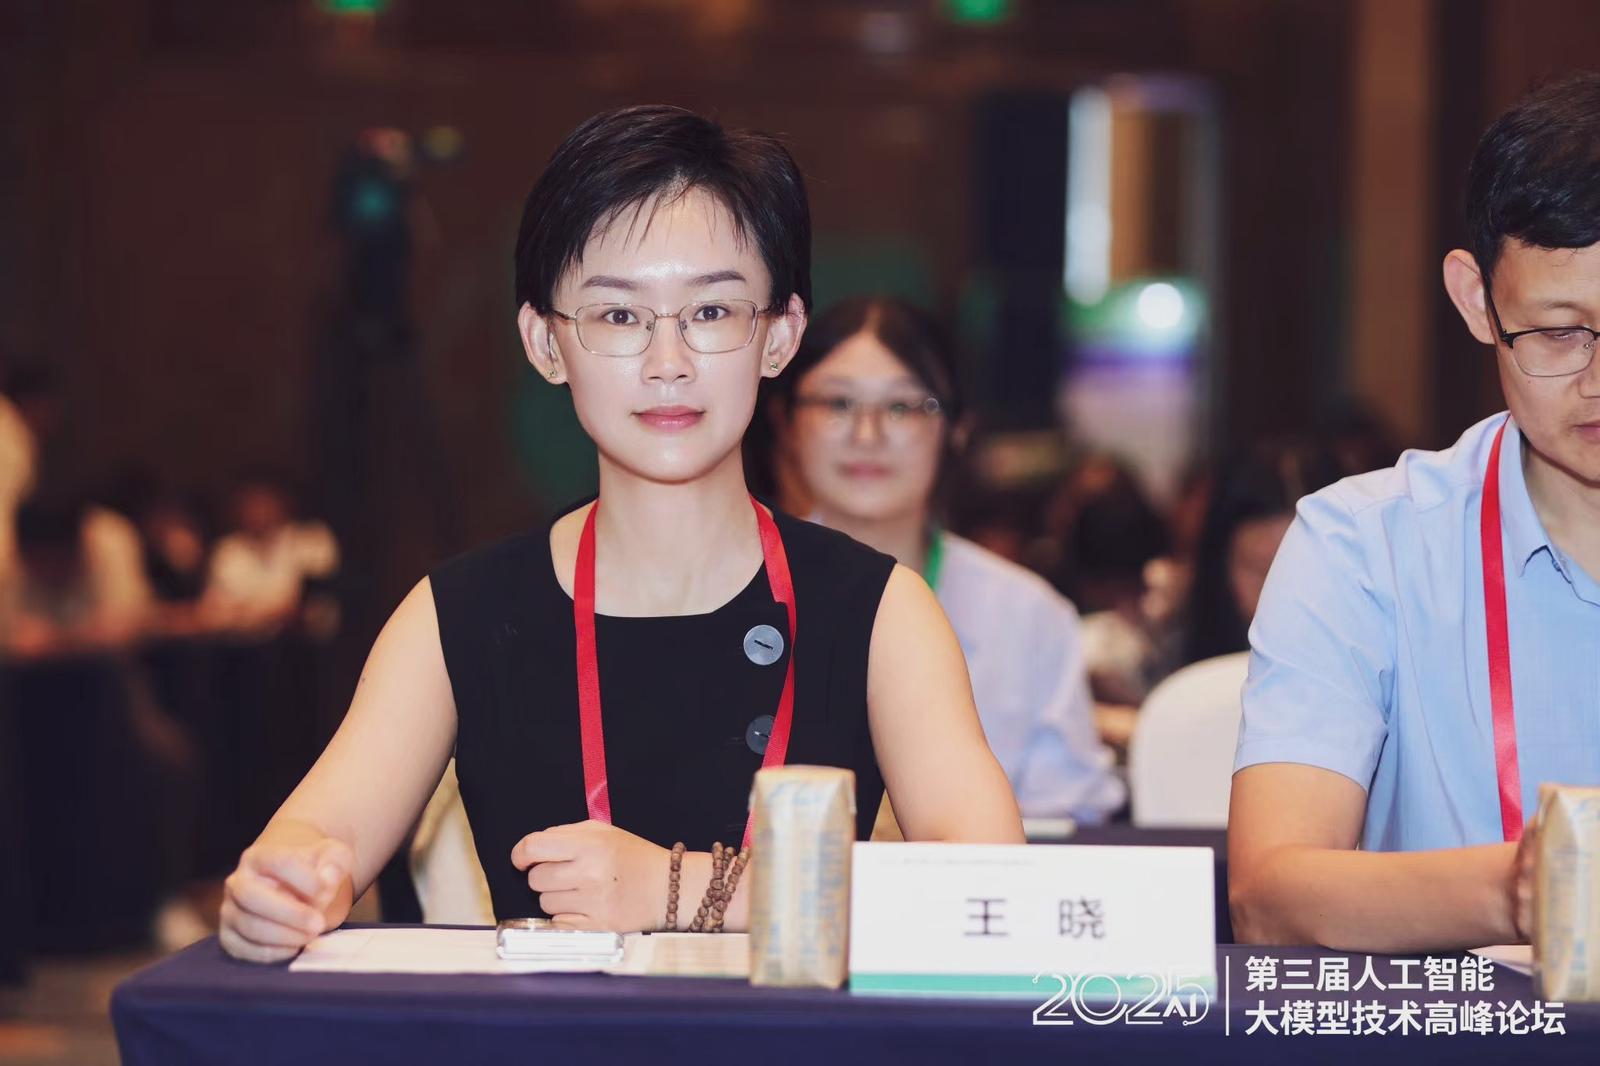
Invited speaker
Anhui University AHU
Presentation
Workshop format
15:15–17:45 · Convention Bureau Stazione Marittima · Aula 5 Room
Tuesday 15 September 2026. All times are local to Naples (CEST). The detailed running order will be added when confirmed.
Framing the research frontier and the central challenges for socially intelligent autonomy.
Technical perspectives spanning human-centered mobility, strategic reasoning, and safe planning.
A collaborative discussion on research priorities, open problems, and paths toward real-world validation.
Organized by
Department of Data and Systems Engineering
The University of Hong Kong
Primary organizer: Prof. Chen Sun
Prof. Chen Sun
The University of Hong Kong
Primary organizer
 Prof. Yang Xing
Cranfield University
Prof. Yukun Lu
University of New Brunswick
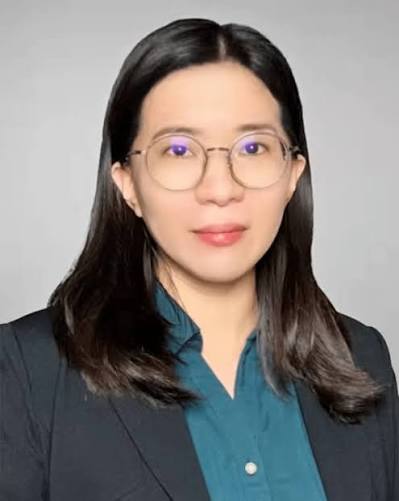 Prof. Chao Huang
University of Adelaide
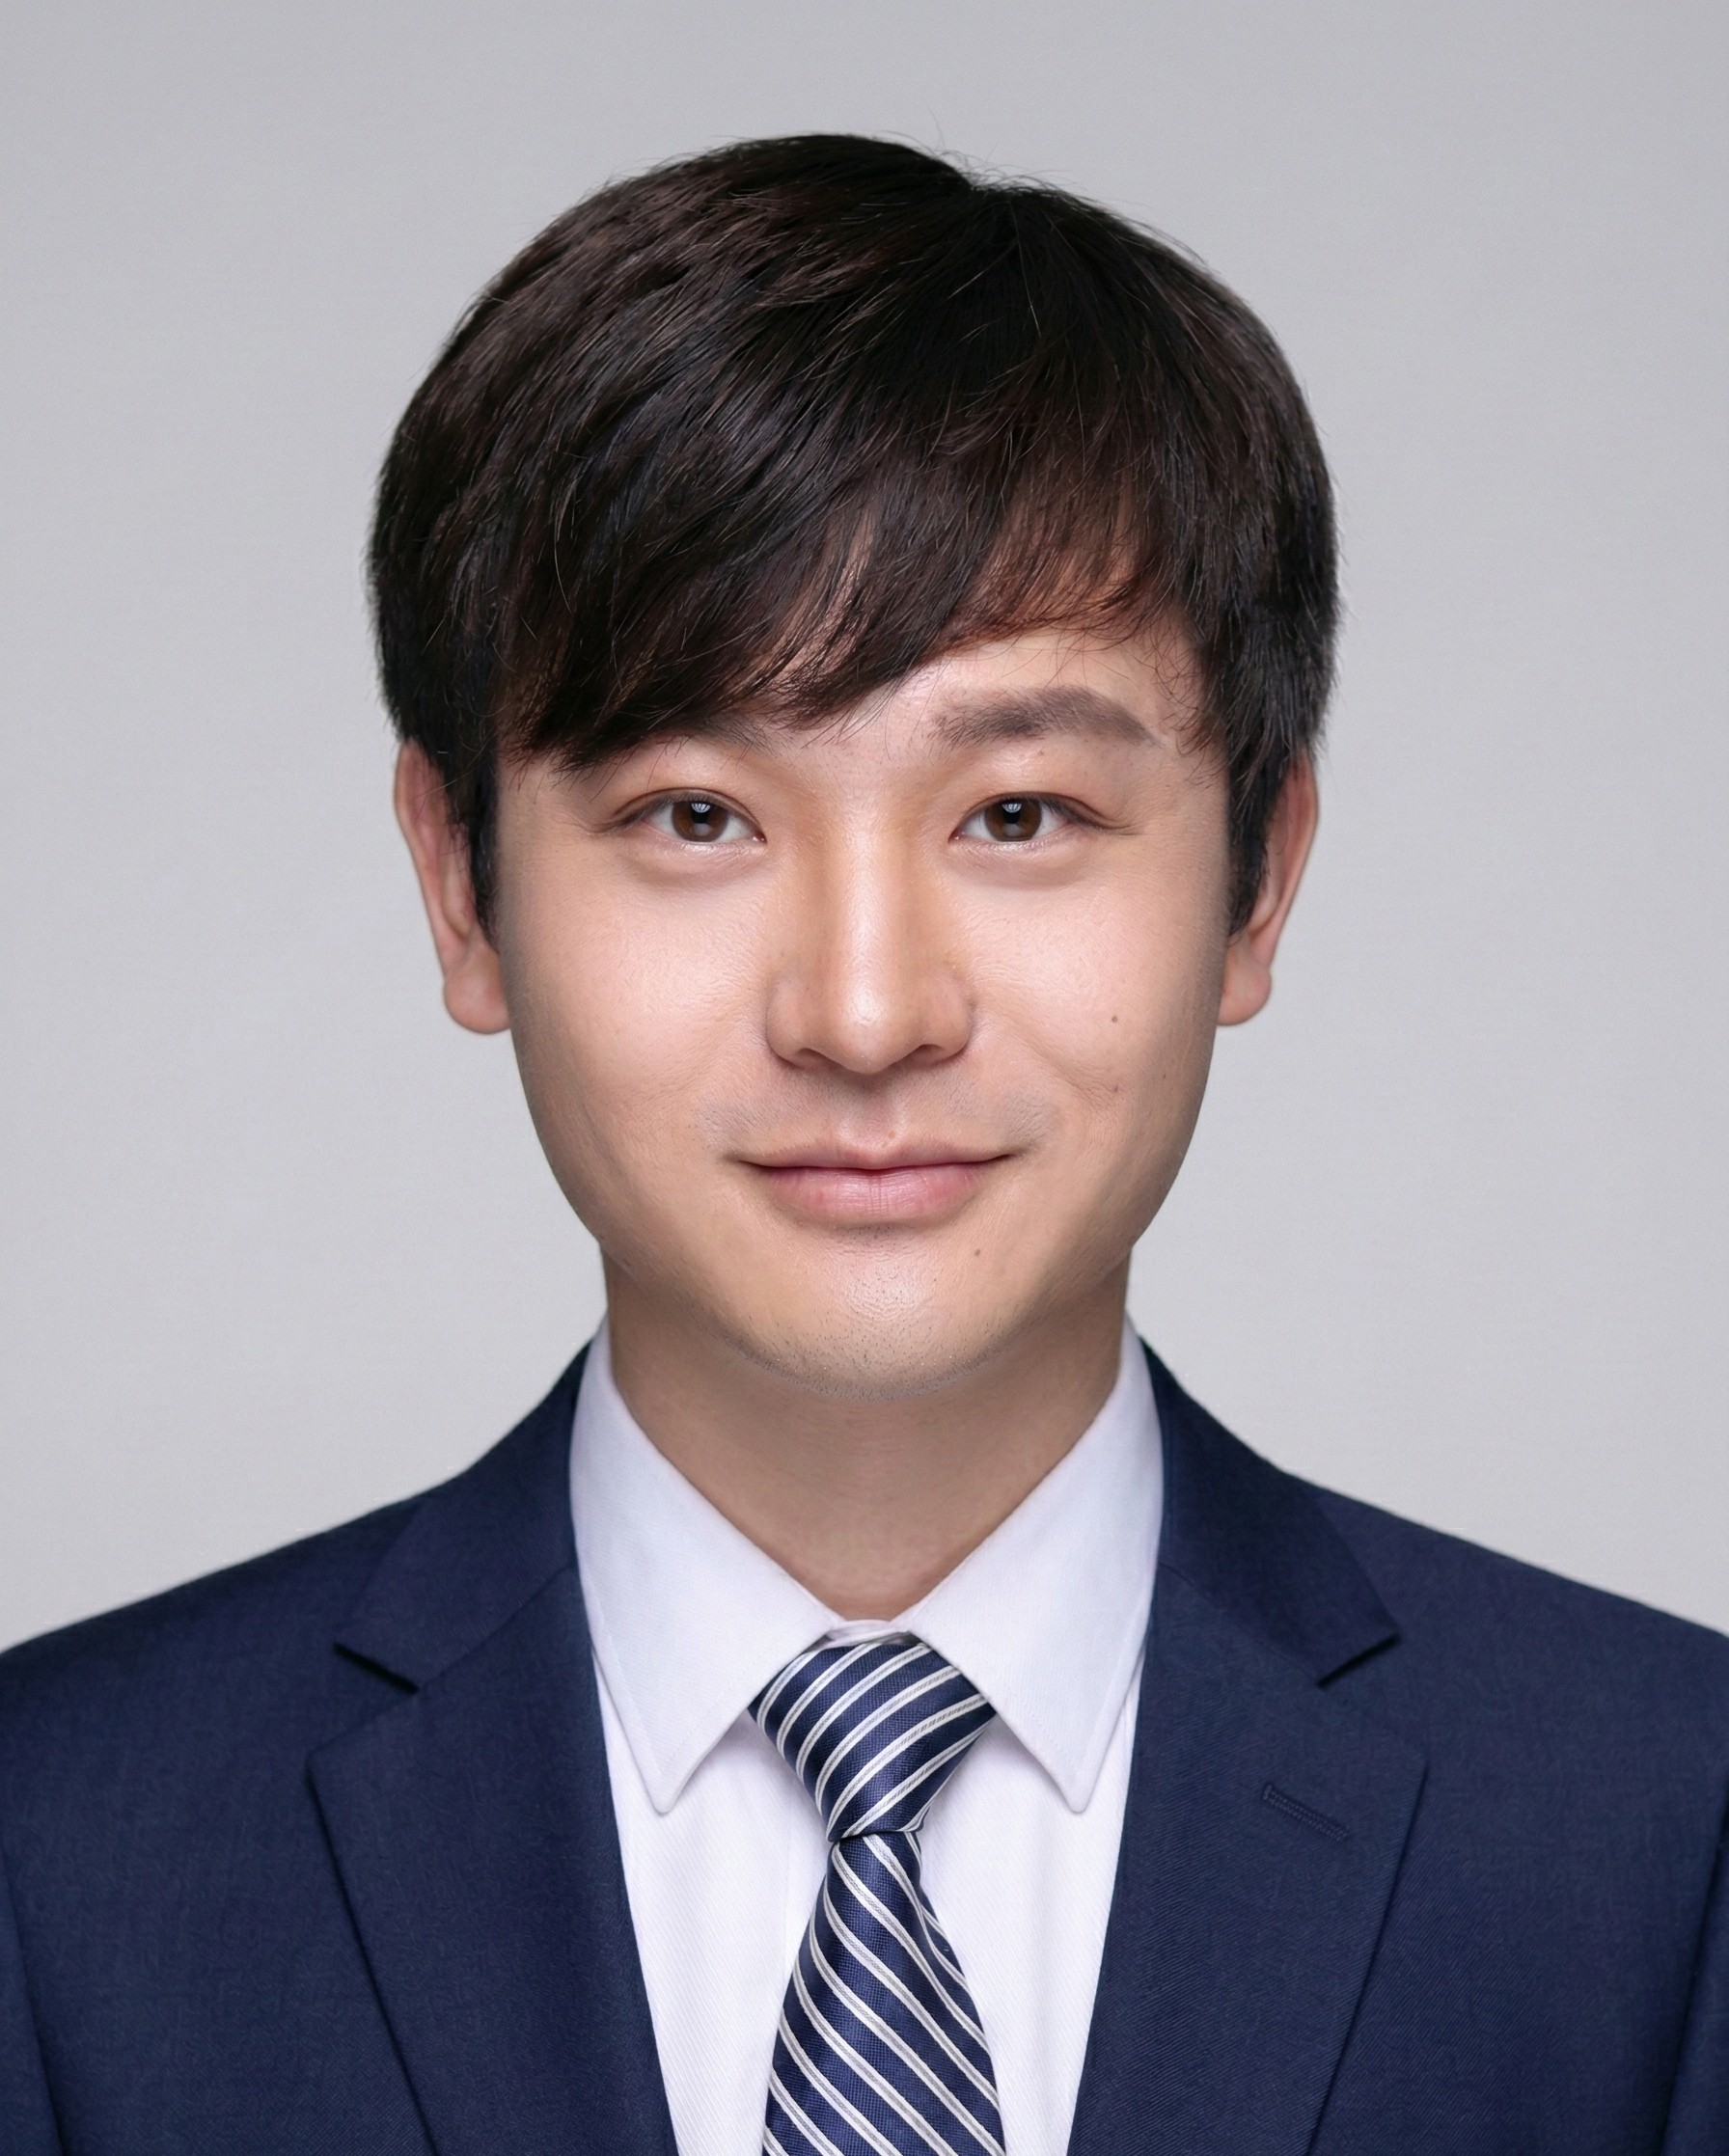 Dr. Guoshun Cai
The University of Hong Kong
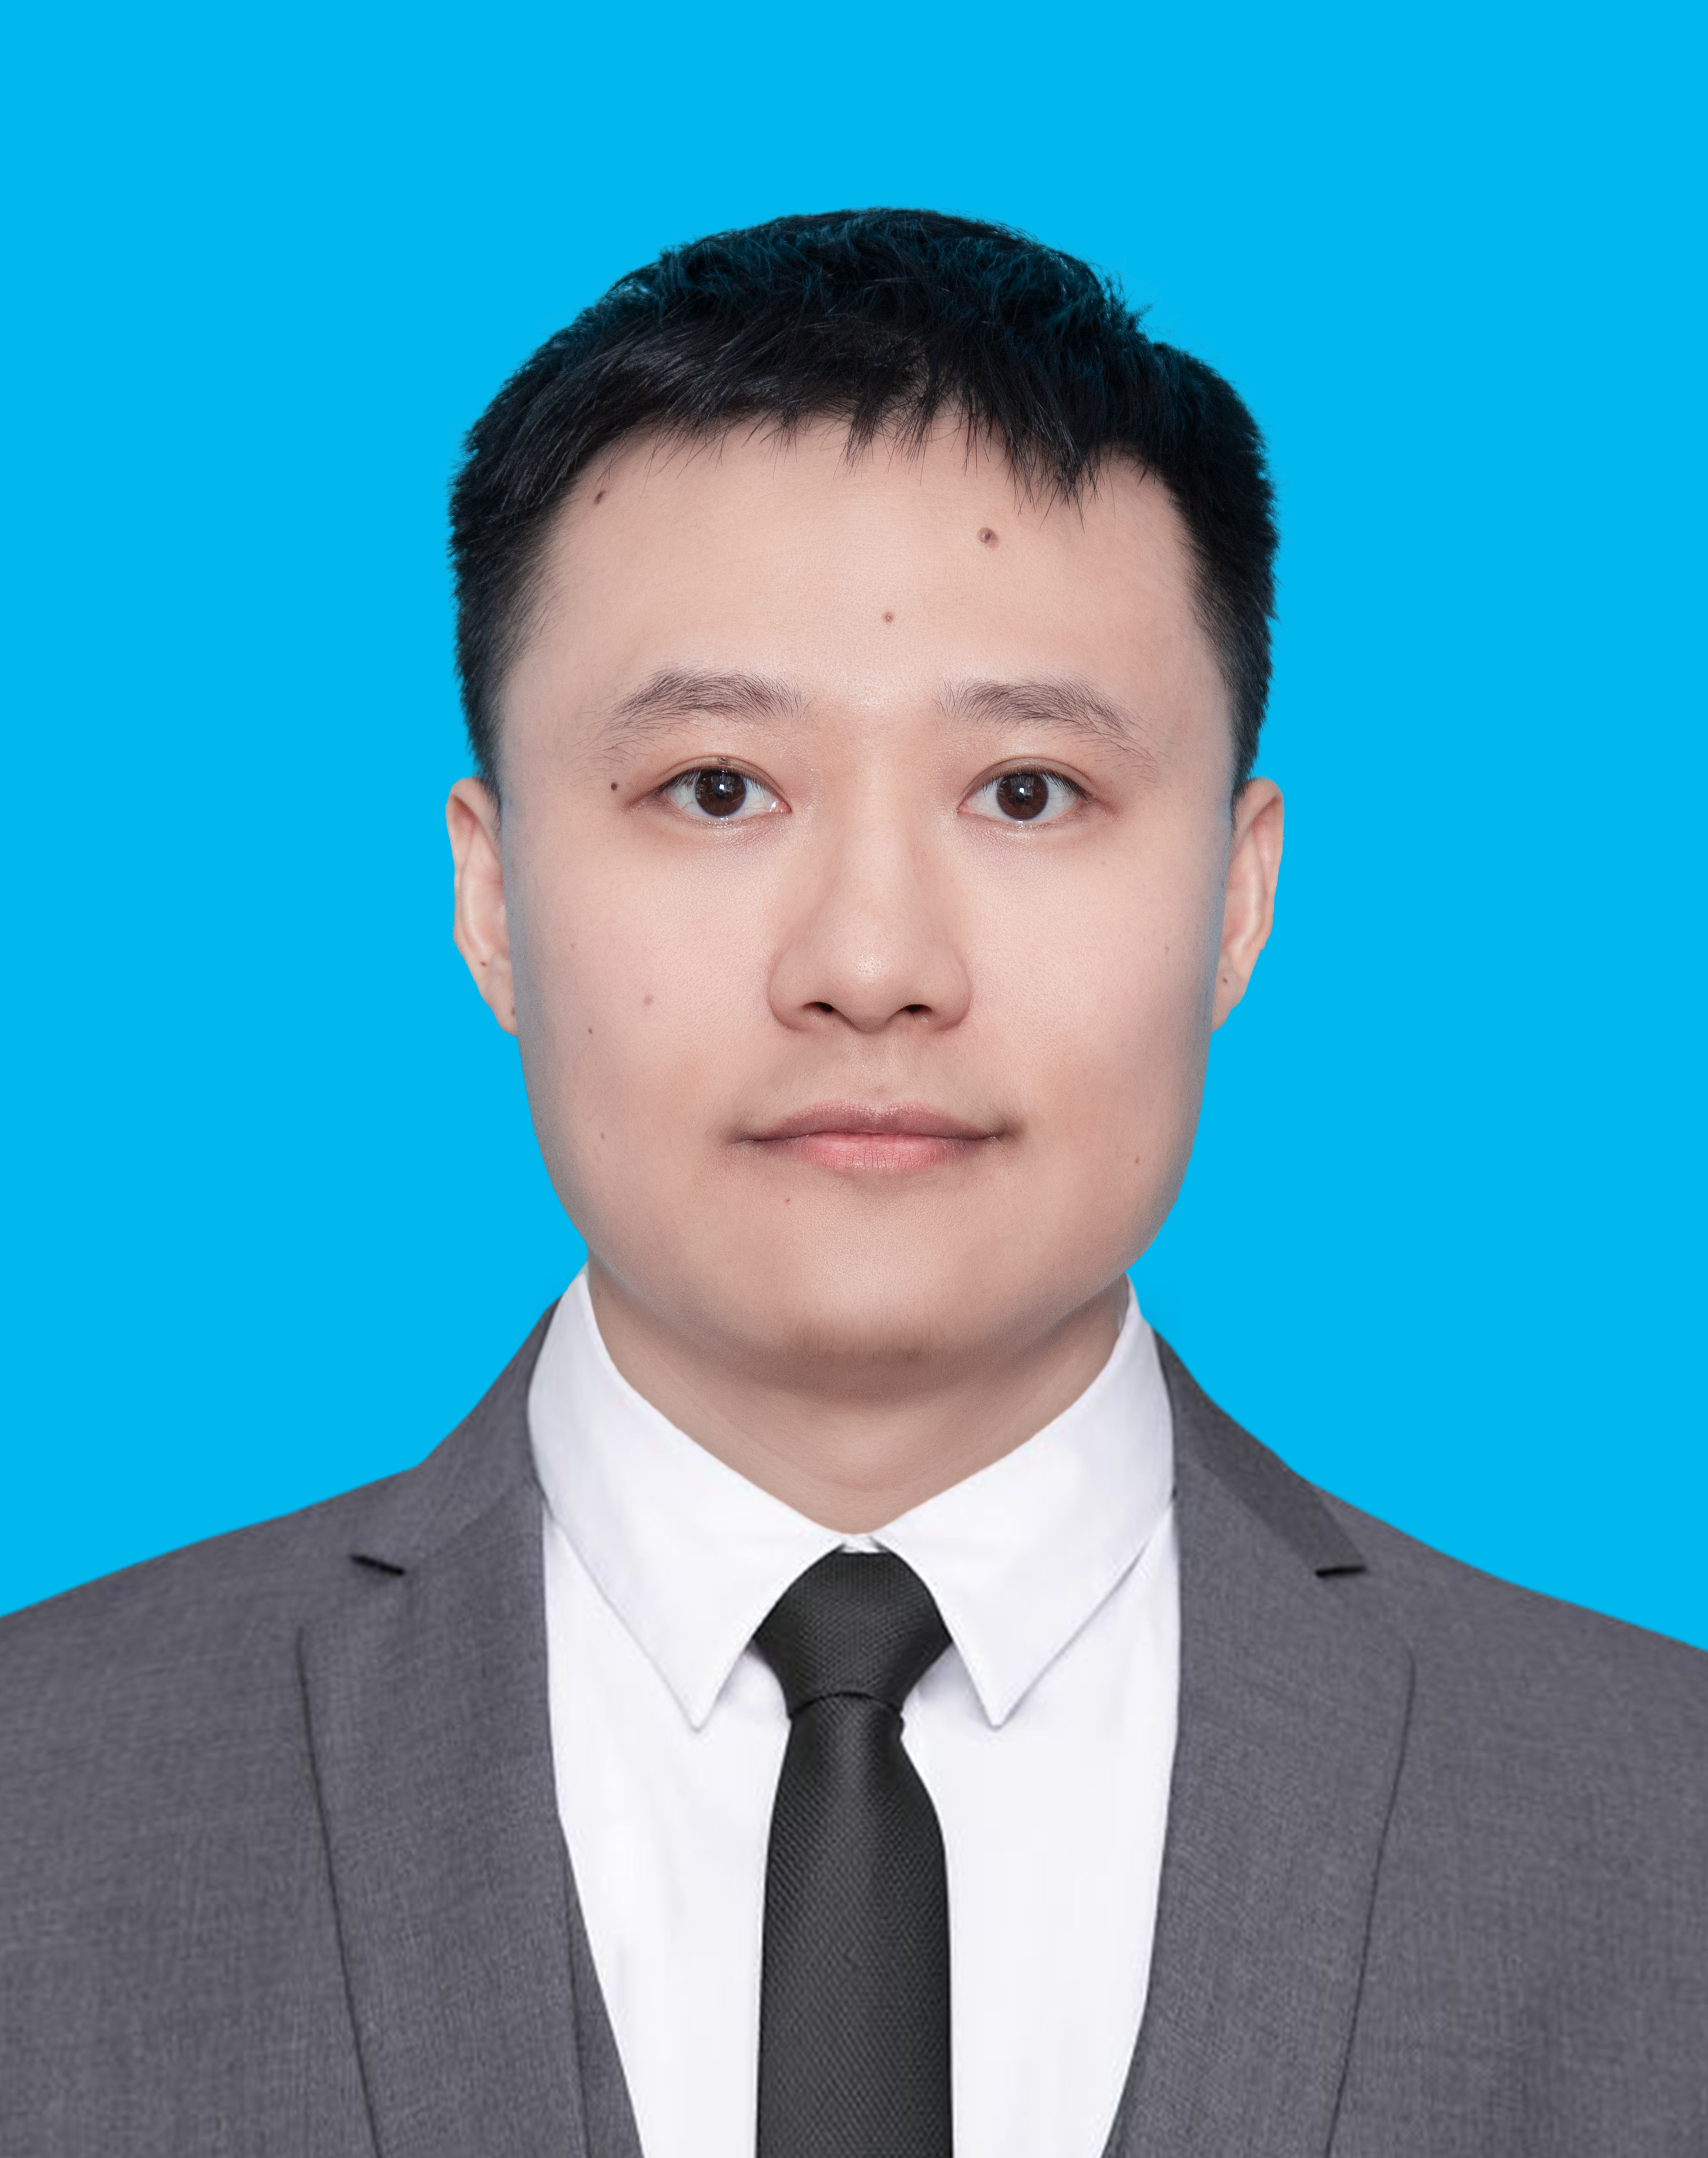 Dr. Zejian Deng
The University of Hong Kong
Join the workshop
Participation requires IEEE ITSC 2026 registration. Please register through the official conference website before attending.
Attendance is in person. The conference does not provide live streaming of workshop sessions.
Official registration informationWe thank the invited speakers, panelists, and participants for contributing to the workshop, and the IEEE ITSC 2026 organizing team for hosting this exchange within the conference programme.
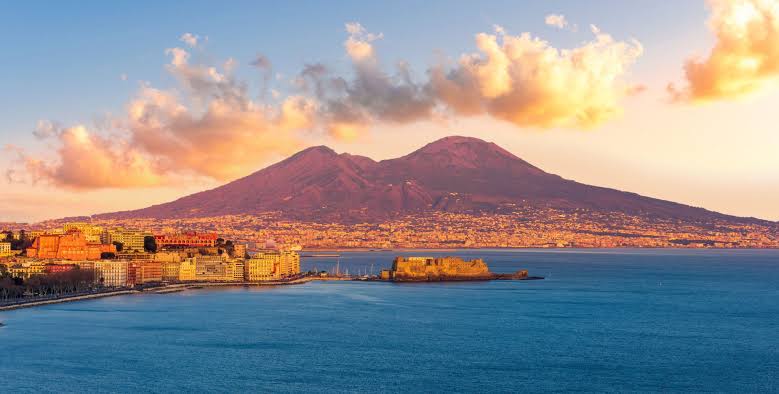
IEEE ITSC 2026
15:15–17:45 · Convention Bureau Stazione Marittima · Aula 5 Room
Tuesday 15 September 2026
Conference: 15–18 September 2026